
Adam Romlein
Senior Research & Development Engineer
Kitware, Inc.
I build real-time computer vision systems that have to work outside the lab: on survey aircraft, drones, ground robots, and underwater vehicles. Since 2024 I've led KAMERA, NOAA's multi-camera aerial survey system for ice seals and whales, and I've spent more than 25 weeks in the field running live operations, including survey flights out of Nome, Alaska. I'm an FAA Part 107 remote pilot and have completed aviation survival and egress training (ASET2).
Portfolio

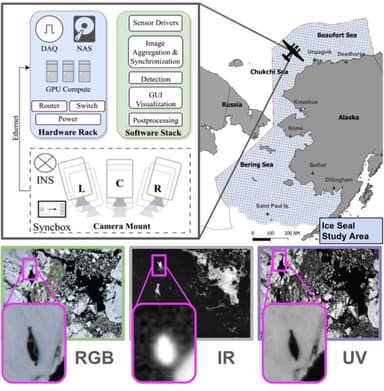
NOAA KAMERA
A multi-camera EO/IR/UV aerial imaging system with real-time onboard detection, flown on NOAA marine mammal surveys in Alaska and the Gulf of Mexico and now running on two aircraft.
Experience
Senior Research and Development Engineer — Kitware, Inc. (Remote)
NOAA KAMERA. I lead KAMERA, the multi-camera EO/IR/UV aerial survey system that AFSC's Marine Mammal Laboratory uses to survey seals and whales. I upgraded the system to Phase One cameras for more pixels on target during species classification, then built and validated a complete second imaging system so two aircraft can survey at the same time, and extended DIVE/VIAME with KAMERA-specific features. The work keeps me close to the field: three weeks of ice seal surveys out of Nome, Alaska, two weeks of Rice's whale surveys in Florida and Texas, and another four weeks on-site with MML staff in Lakeland and Seattle developing and duplicating the system.
U.S. Army C5ISR Countermine. I lead relocalization and mapping on a Phase II SBIR for UAS-based landmine detection, where I built a pipeline that matches live imagery to prebuilt SfM and orthoimagery maps using SIFT/FAISS tile indexing, coarse homography, and RoMaV2 dense refinement, benchmarked on Jetson Orin. I was also technical lead on a separate Phase II effort for long-term tracking and re-identification in UAS video.
AFRL TAKML. I connected our edge-deployed URSA tracker to the ARCTAK ATAK plugin, publishing person tracks, re-ID matches, and live alerts through TAK Server.
Research and Development Engineer — Kitware, Inc. (Hybrid, Clifton Park, NY)
DARPA URSA. As lead systems engineer, I deployed TensorRT-optimized detection, tracking, and activity-recognition models onto Jetson Xavier platforms via ROS/Python and orchestrated a network of over 24 mobile (UGV, UAV) and fixed PTZ cameras. I owned more than a dozen Git repositories and their Docker containerization, supervised three OSTP interns building a tracking UI, and helped carry the system to TRL 6 over 20+ weeks of field testing.
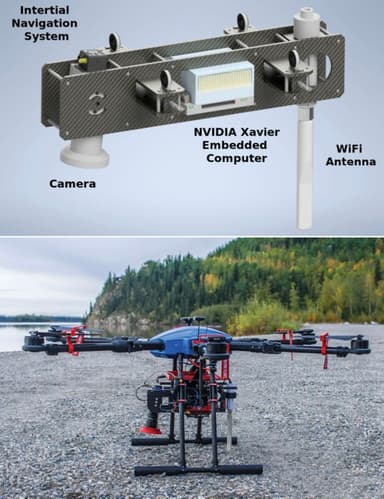
NOAA KAMERA. As a core developer, I worked directly with NOAA scientists to mature the system from research code into a stable, modular stack, and adapted it for NASA's SIERRA-B large UAS.
NOAA ADAPT. That same stack became the basis for ADAPT, a modular sUAS payload for ice-floe mapping built with the University of Alaska Fairbanks.
DARPA ANGLER. I led integration, assembling and operating a BlueROV2 with a tethered Jetson Xavier for underwater data collection and in-water model testing.
Research and Development Intern — Kitware, Inc. (Clifton Park, NY)
I supported system integration on NOAA KAMERA and DARPA URSA, working on Jetson Xavier-based sensing networks.
Research and Development Intern — Kitware, Inc. (Clifton Park, NY)
For DARPA Squad-X, I developed an R-CNN-based person detector using EO/IR fusion for a Clearpath Husky UGV, and built a ROS/Python architecture to replay 9 camera streams synchronously across 3 hardware nodes. I also supported data collection for DARPA DIVA, gathering multi-modal camera streams for activity recognition.
Technical Intern — Knolls Atomic Power Laboratory (Niskayuna, NY)
I was design lead on equipment for examining spent nuclear fuel components, owning the mechanical design and its integration with existing systems under a Naval Reactors safety culture.
Education
Clarkson University
B.S. in Computer Engineering, minor in Mathematics.
Conducted undergraduate research with Dr. Luke Rumbaugh, gaining hands-on experience across multiple 3D vision systems, including stereoscopic, time of flight, laser line scanner, structured light, and structure from motion.
Publications
IEEE Winter Conference on Applications of Computer Vision (WACV) 2019
Multi-Modal Detection Fusion on a Mobile UGV for Wide-Area, Long-Range Surveillance
M. Brown, K. Fieldhouse, E. Swears, P. Tunison, A. Romlein, and A. Hoogs